|
|
|
| 3D point cloud-based trajectory planning method for personalized pattern spraying on complex surfaces |
Zeyi YANG( ),Zhengdong ZHOU*(),Xiaoxi YUAN,Zhi CAI,Mengyao YUAN |
| State Key Laboratory of Mechanics and Control for Mechanical Structures, Nanjing University of Aeronautics and Astronautics, Nanjing 210016, China |
|
|
|
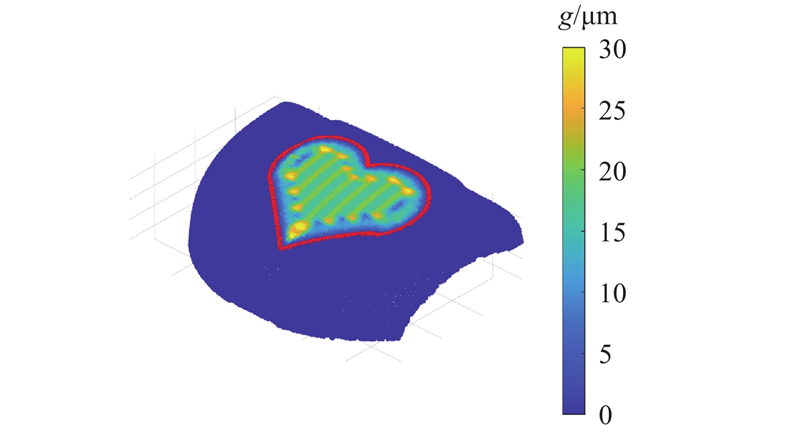
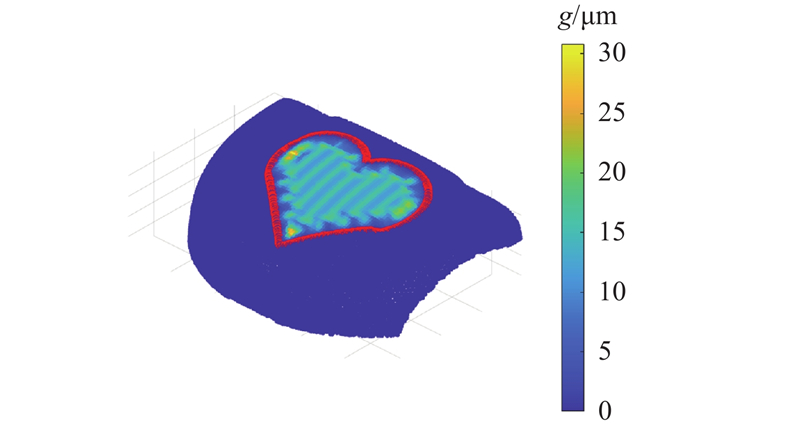
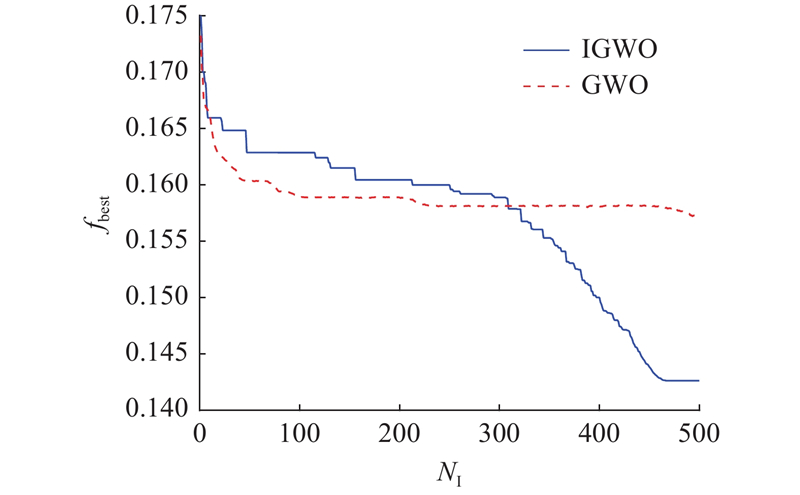
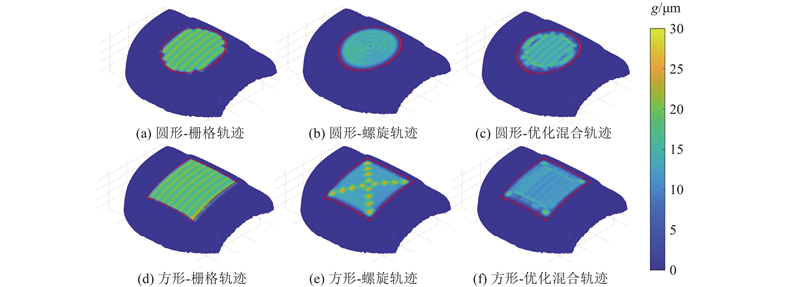
Abstract To improve the accuracy and uniformity of personalized spraying on complex surfaces, a spraying trajectory planning and optimization method integrating raster and spiral trajectories was proposed. A coating accumulation prediction model for complex surfaces was first constructed based on the elliptical double-β model. Then, a high-precision hybrid spraying trajectory suitable for complex surfaces was designed by combining the respective advantages of raster and spiral trajectories. On this basis, the spraying spacing and spraying speed of the raster trajectory, as well as the spraying speed of the spiral trajectory, were optimized using sequential quadratic programming and an improved grey wolf optimization algorithm (IGWO). Simulation results show that the optimized hybrid trajectory provides excellent edge accuracy and coating uniformity for heart-shaped, square, and circular patterns. For the heart-shaped pattern, the edge error was reduced by 59.36%, and the coating thickness variation was reduced by 15.33% compared with the traditional raster trajectory, while the coating thickness variation was reduced by 75.87% compared with the spiral trajectory. The proposed method exhibits consistent and stable performance across patterns with different geometric features, demonstrating its universality and effectiveness for personalized spraying on complex surfaces.
|
|
Received: 16 September 2025
Published: 16 October 2026
|
|
|
| Fund: 国家自然科学基金资助项目(52375570);中国航空研究院首批揭榜挂帅项目(F2021109);上海航天科技创新基金资助项目(SAST2019-121);南京航空航天大学研究生科研与实践创新计划项目(xcxjh20240110);江苏高校优势学科建设工程资助项目(PAPD). |
|
Corresponding Authors:
Zhengdong ZHOU
E-mail: yzy123@nuaa.edu.cn;zzd_msc@nuaa.edu.cn
|
基于3D点云复杂曲面的个性化图案喷涂轨迹规划方法
为了提高复杂曲面个性化图案喷涂的精度与均匀性,提出融合栅格型轨迹与螺旋型轨迹的喷涂轨迹规划及优化方法. 基于椭圆双β模型构建复杂曲面涂料堆积分布预测模型. 结合栅格轨迹与螺旋轨迹各自的优势,设计适用于复杂曲面的高精度混合喷涂轨迹. 运用序列二次规划法与改进的灰狼优化算法(IGWO),分别对栅格型轨迹的喷涂间距与喷涂速度以及螺旋型轨迹的喷涂速度进行优化. 仿真实验结果表明:优化后的混合轨迹在心形、方形及圆形等复杂图案中均表现出优异的边缘精度与涂层均匀性,其中心形图案的图案边缘误差相比传统栅格轨迹降低59.36%,涂层厚度变异降低15.33%,相比螺旋轨迹涂层厚度变异降低75.87%. 所提方法在不同几何特征图案中均表现出一致且稳定的性能,验证了其在复杂曲面个性化喷涂中的普适性与有效性.
关键词:
轨迹规划,
3D点云,
复杂曲面,
喷涂机器人,
图案喷涂
|
|
| [1] |
CHEN H, SHENG W, XI N, et al. Automated robot trajectory planning for spray painting of free-form surfaces in automotive manufacturing [C]// Proceedings of the Proceedings 2002 IEEE International Conference on Robotics and Automation. Washington: IEEE, 2002: 450–455.
|
|
|
| [2] |
MIRZAAKHMEDOV M M U Optimizing the implementation of robotic aircraft painting systems solutions and strategies[J]. Bulletin News in New Science Society International Scientific Journal, 2025, 2 (9): 22- 30
|
|
|
| [3] |
KONG M, LI A, GAO F. A trajectory planning algorithm of spray robot for workpieces with complex geometric features based on 3D point cloud [C]// Proceedings of the IEEE 5th Information Technology, Networking, Electronic and Automation Control Conference. Xi’an: IEEE, 2021: 13–20.
|
|
|
| [4] |
石仲川, 刘德鑫, 张晓云, 等 冷喷涂技术的研究现状及在航空工业领域内的应用[J]. 材料导报, 2012, 26 (17): 70- 74
SHI Zhongchuan, LIU Dexin, ZHANG Xiaoyun, et al Research of cold gas dynamic spray technology and its application in aviation industry[J]. Materials Review, 2012, 26 (17): 70- 74
doi: 10.3969/j.issn.1005-023X.2012.17.015
|
|
|
| [5] |
AKAFUAH N K, POOZESH S, SALAIMEH A, et al Evolution of the automotive body coating process: a review[J]. Coatings, 2016, 6 (2): 24
doi: 10.3390/coatings6020024
|
|
|
| [6] |
YAO Z, SONG Y, GAO Y, et al. Process research on intelligent coating robot system for ship segments [C]// Proceedings of the International Conference on Automation Control, Algorithm, and Intelligent Bionics. Xiamen: SPIE, 2023: 64.
|
|
|
| [7] |
赵景山, 魏松涛, 赵东捷, 等 超大作业空间涂装机器人研究进展[J]. 航空制造技术, 2023, 66 (12): 46- 58
ZHAO Jingshan, WEI Songtao, ZHAO Dongjie, et al Research advancement of coating robot for super large space[J]. Aeronautical Manufacturing Technology, 2023, 66 (12): 46- 58
doi: 10.16080/j.issn1671-833x.2023.12.046
|
|
|
| [8] |
UANG S N, SHIH T S, CHANG C H, et al Exposure assessment of organic solvents for aircraft paint stripping and spraying workers[J]. Science of the Total Environment, 2006, 356 (1/2/3): 38- 44
|
|
|
| [9] |
刘亚军, 訾斌, 王正雨, 等 智能喷涂机器人关键技术研究现状及进展[J]. 机械工程学报, 2022, 58 (7): 53- 74
LIU Yajun, ZI Bin, WANG Zhengyu, et al Research progress and trend of key technology of intelligent spraying robot[J]. Journal of Mechanical Engineering, 2022, 58 (7): 53- 74
doi: 10.3901/JME.2022.07.053
|
|
|
| [10] |
YU X, CHENG Z, ZHANG Y, et al Point cloud modeling and slicing algorithm for trajectory planning of spray painting robot[J]. Robotica, 2021, 39 (12): 2246- 2267
doi: 10.1017/S0263574721000308
|
|
|
| [11] |
LIU Z, CHENG S, SU Y, et al Semantic segmentation based spraying trajectory planning for complex product[J]. IEEE Transactions on Industrial Informatics, 2024, 20 (7): 9416- 9426
doi: 10.1109/TII.2024.3383865
|
|
|
| [12] |
NIETO BASTIDA S, LIN C Y Autonomous trajectory planning for spray painting on complex surfaces based on a point cloud model[J]. Sensors, 2023, 23 (24): 9634
doi: 10.3390/s23249634
|
|
|
| [13] |
HUA R X, MA H X, ZOU W, et al A spraying path planning algorithm based on point cloud segmentation and trajectory sequence optimization[J]. International Journal of Control, Automation and Systems, 2024, 22 (2): 615- 630
doi: 10.1007/s12555-022-0203-8
|
|
|
| [14] |
KUANG Y, WANG C, LIU L. Path planning method for complex surface spraying [C]// Proceedings of the 2nd International Conference on Artificial Intelligence and Automation Control. Guangzhou: IEEE, 2025: 107–112.
|
|
|
| [15] |
XU F, ZI B, WANG J, et al Multi-objective trajectory optimization for rigid-flexible coupling spray-painting robot integrated with coating process constraints[J]. Chinese Journal of Mechanical Engineering, 2024, 37 (1): 152
doi: 10.1186/s10033-024-01130-5
|
|
|
| [16] |
ZHANG S, XIA Q, CHEN M, et al Multi-objective optimal trajectory planning for robotic arms using deep reinforcement learning[J]. Sensors, 2023, 23 (13): 5974
doi: 10.3390/s23135974
|
|
|
| [17] |
WANG S, XU Z, WANG Y, et al Model-enabled robotic machining framework for repairing paint film defects[J]. Robotics and Computer-Integrated Manufacturing, 2024, 89: 102791
doi: 10.1016/j.rcim.2024.102791
|
|
|
| [18] |
BHAT R, KARUPPASAMY M, MARAGATHARAJAN M, et al Optimization of robotic spray painting trajectories using machine learning for improved surface quality[J]. Scientific Reports, 2025, 15: 18767
doi: 10.1038/s41598-025-03448-z
|
|
|
| [19] |
ANTONIO J K. Optimal trajectory planning for spray coating[C]// Proceedings of the 1994 IEEE International Conference on Robotics and Automation. San Diego: IEEE, 1994: 2570–2577.
|
|
|
| [20] |
FREUND E, ROKOSSA D, ROSSMANN J. Process-oriented approach to an efficient off-line programming of industrial robots [C]// Proceedings of the IECON '98. Proceedings of the 24th Annual Conference of the IEEE Industrial Electronics Society. Aachen: IEEE, 2002: 208–213.
|
|
|
| [21] |
SAHIR ARIKAN M A, BALKAN T Process modeling, simulation, and paint thickness measurement for robotic spray painting[J]. Journal of Robotic Systems, 2000, 17 (9): 479- 494
doi: 10.1002/1097-4563(200009)17:9<479::AID-ROB3>3.0.CO;2-L
|
|
|
| [22] |
SAHIR ARIKAN M A, BALKAN T Modeling of paint flow rate flux for elliptical paint sprays by using experimental paint thickness distributions[J]. Industrial Robot, 2006, 33 (1): 60- 66
doi: 10.1108/01439910610638243
|
|
|
| [23] |
LI M Z, LU Z P, SHA C F, et al Trajectory generation of spray painting robot using point cloud slicing[J]. Applied Mechanics and Materials, 2010, 44/45/46/47: 1290- 1294
doi: 10.4028/www.scientific.net/amm.44-47.1290
|
|
|
|
Viewed |
|
|
|
Full text
|
|
|
|
|
Abstract
|
|
|
|
|
Cited |
|
|
|
|
| |
Shared |
|
|
|
|
| |
Discussed |
|
|
|
|